
Applications
Capability begins with a clear purpose.
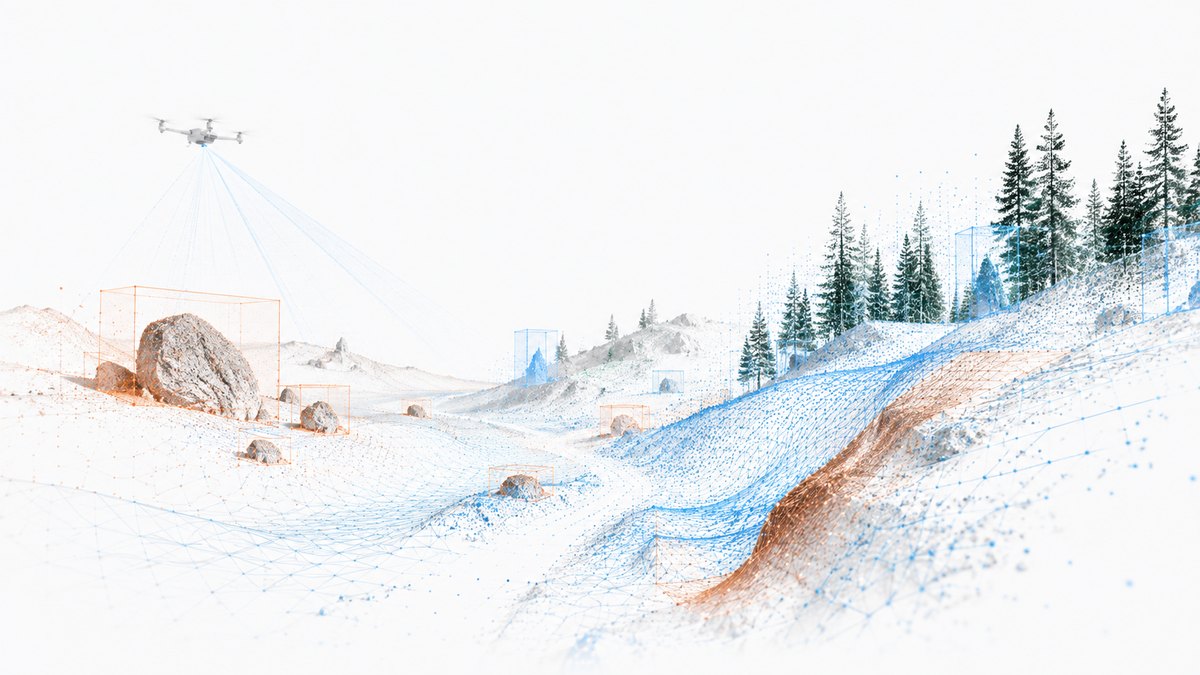
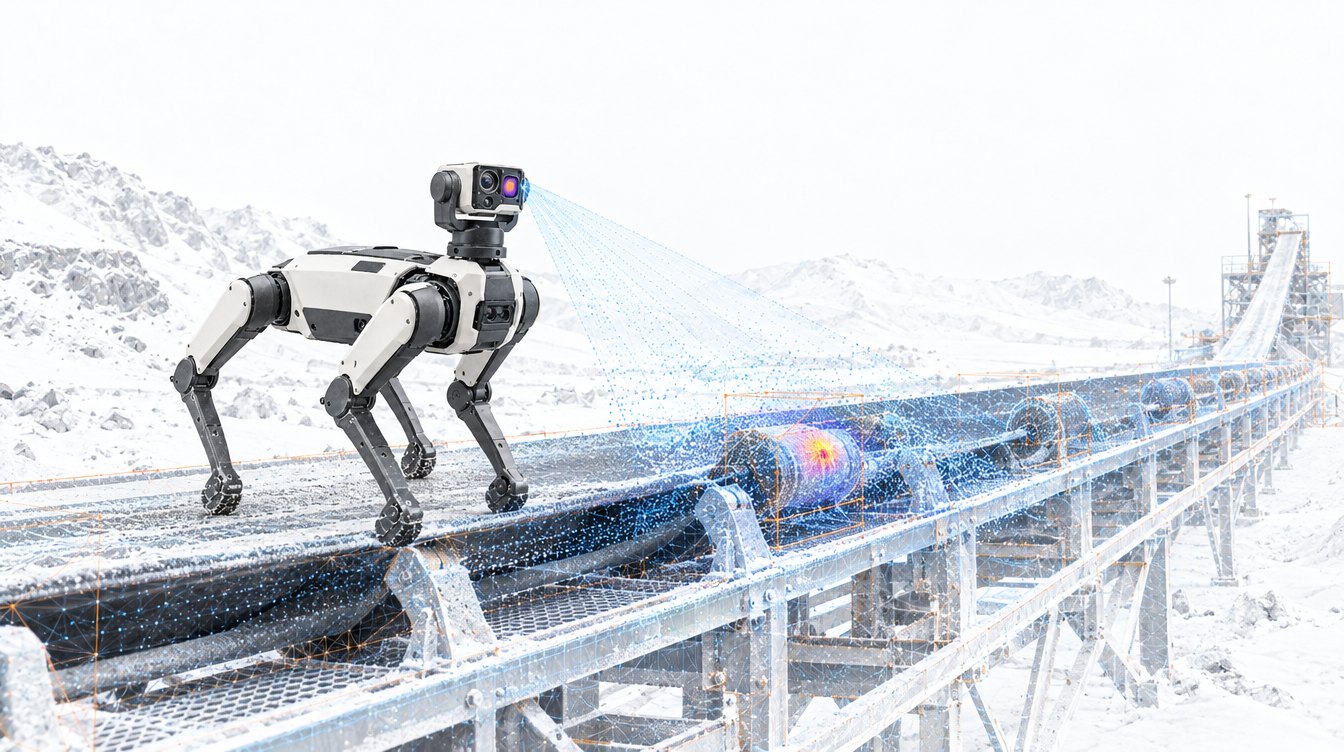
Our robots go where people shouldn’t go first. They check gas and radiation, map mines and buildings in 3D, and stream the live view to the operator.
Across mining, industry, security, research, and emergency response, the starting point is the same: understand the work before defining the system.
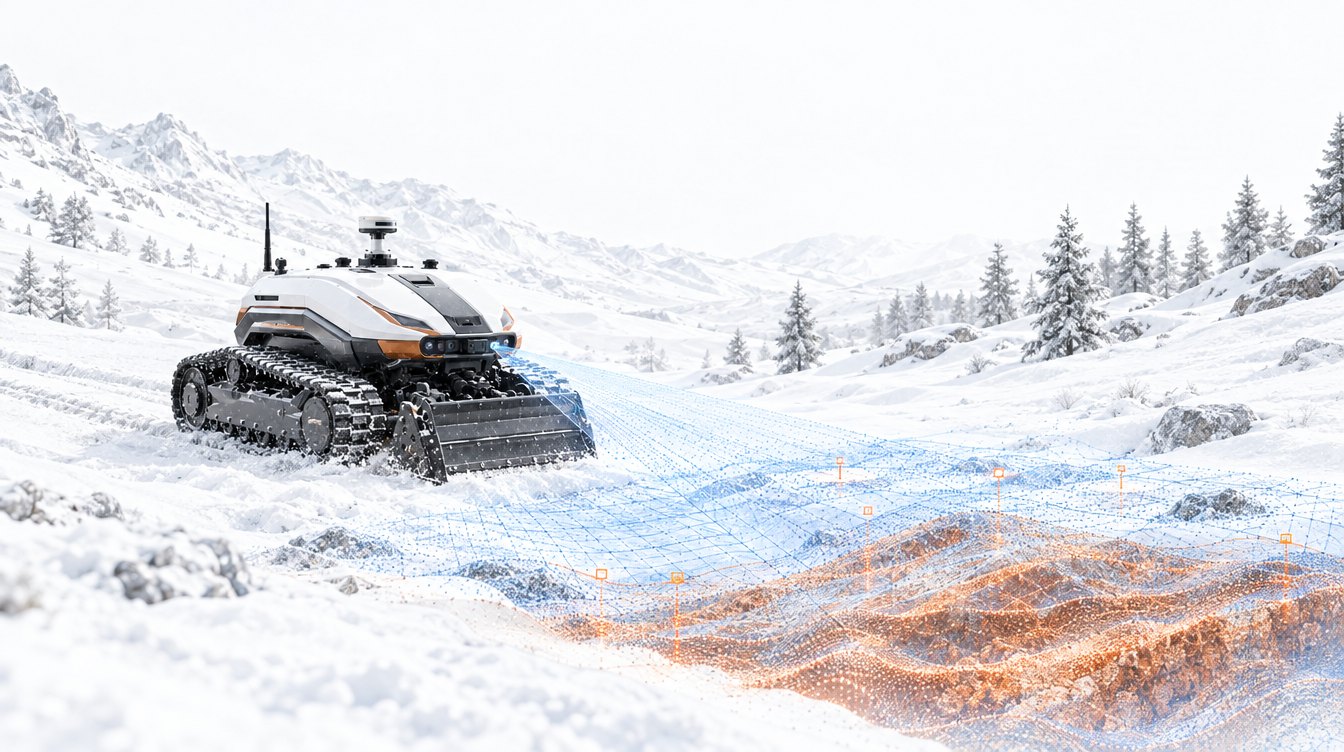
05 · Ground preparation and access
Prepare the way for the next operation.
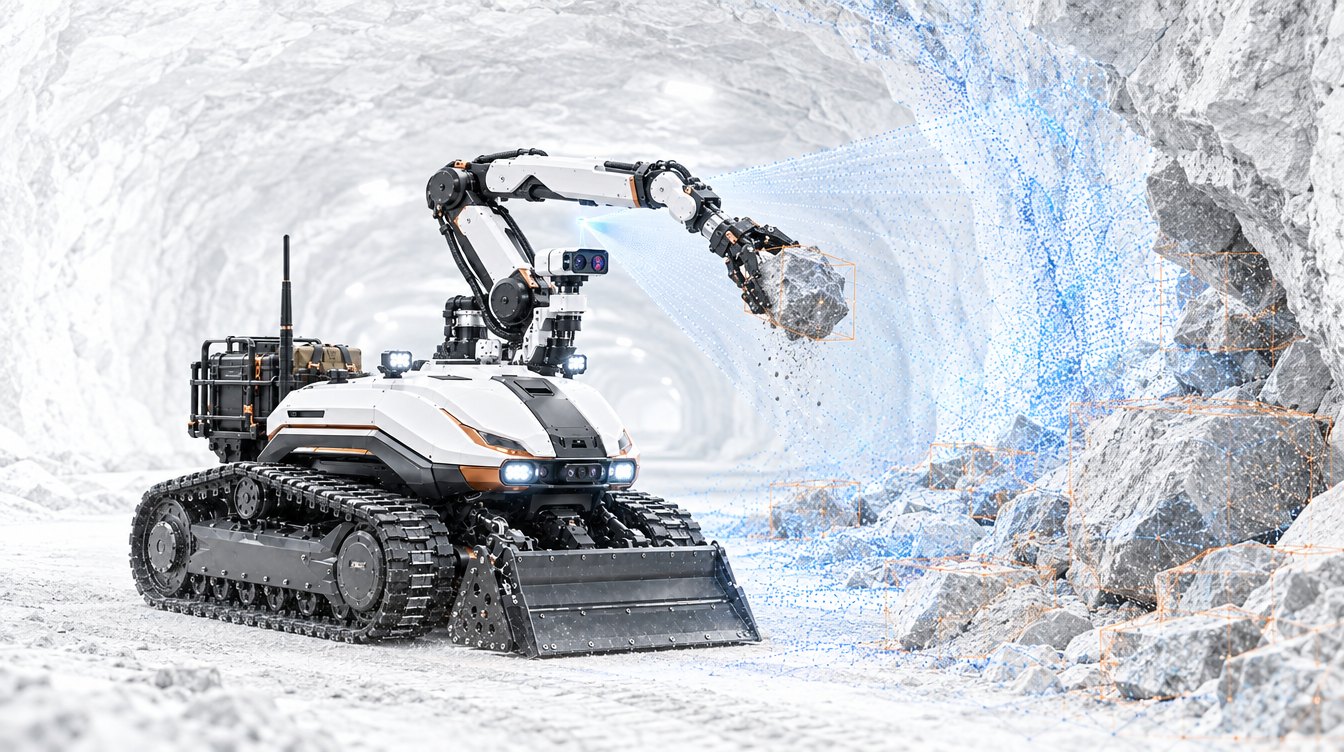
A tracked platform with a front blade could support loose-material clearing, surface leveling, and access-route preparation through controlled movement and operator supervision.
Relevant system
Nox
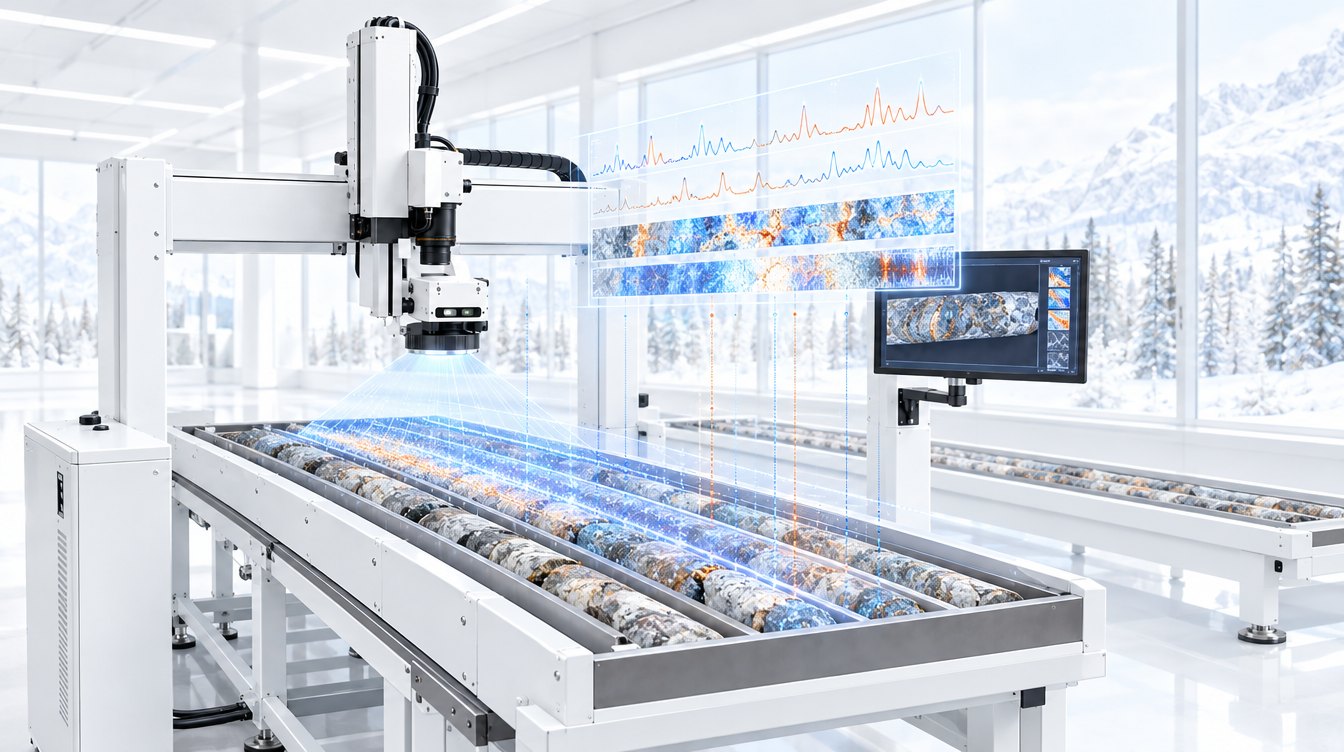
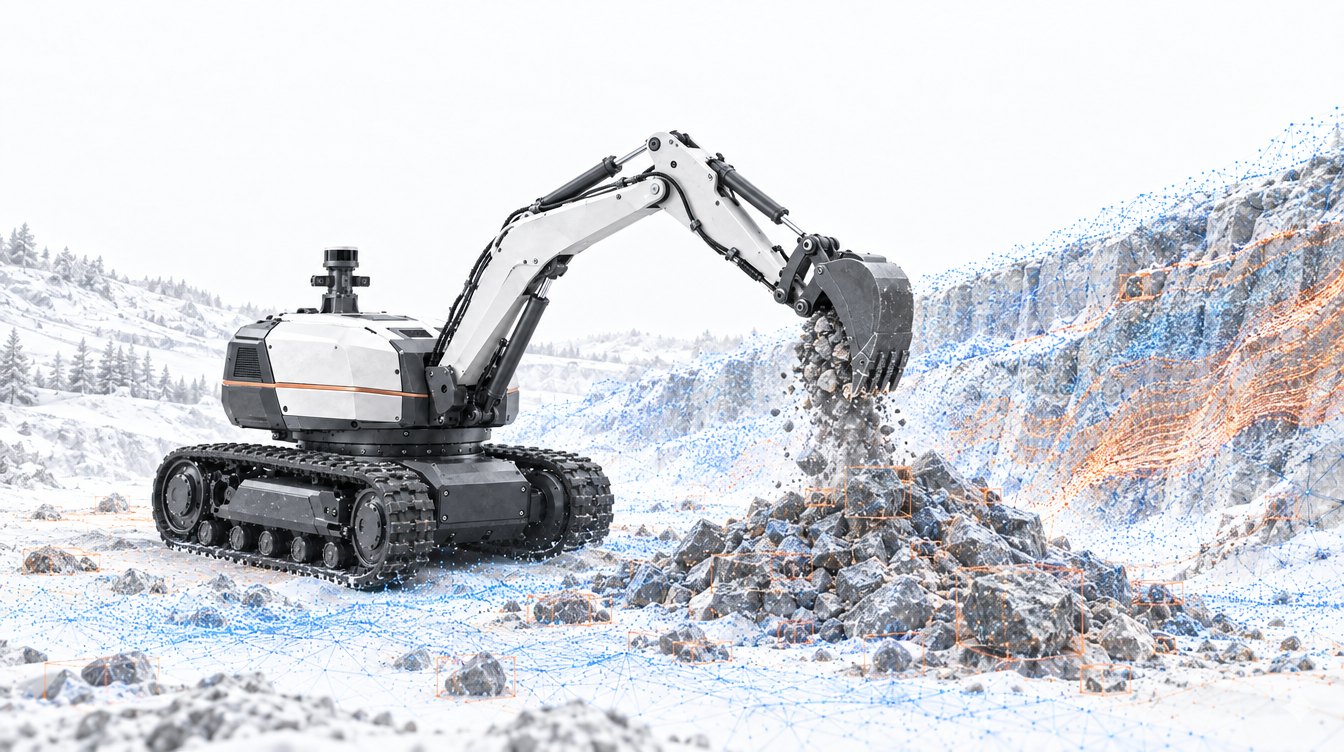
07 · Excavation and material handling
Bring greater control to physical work.
Robotic excavation could support digging, trench preparation, and material movement within defined work areas, informed by terrain sensing and supervised tool control.
Relevant system
Aster
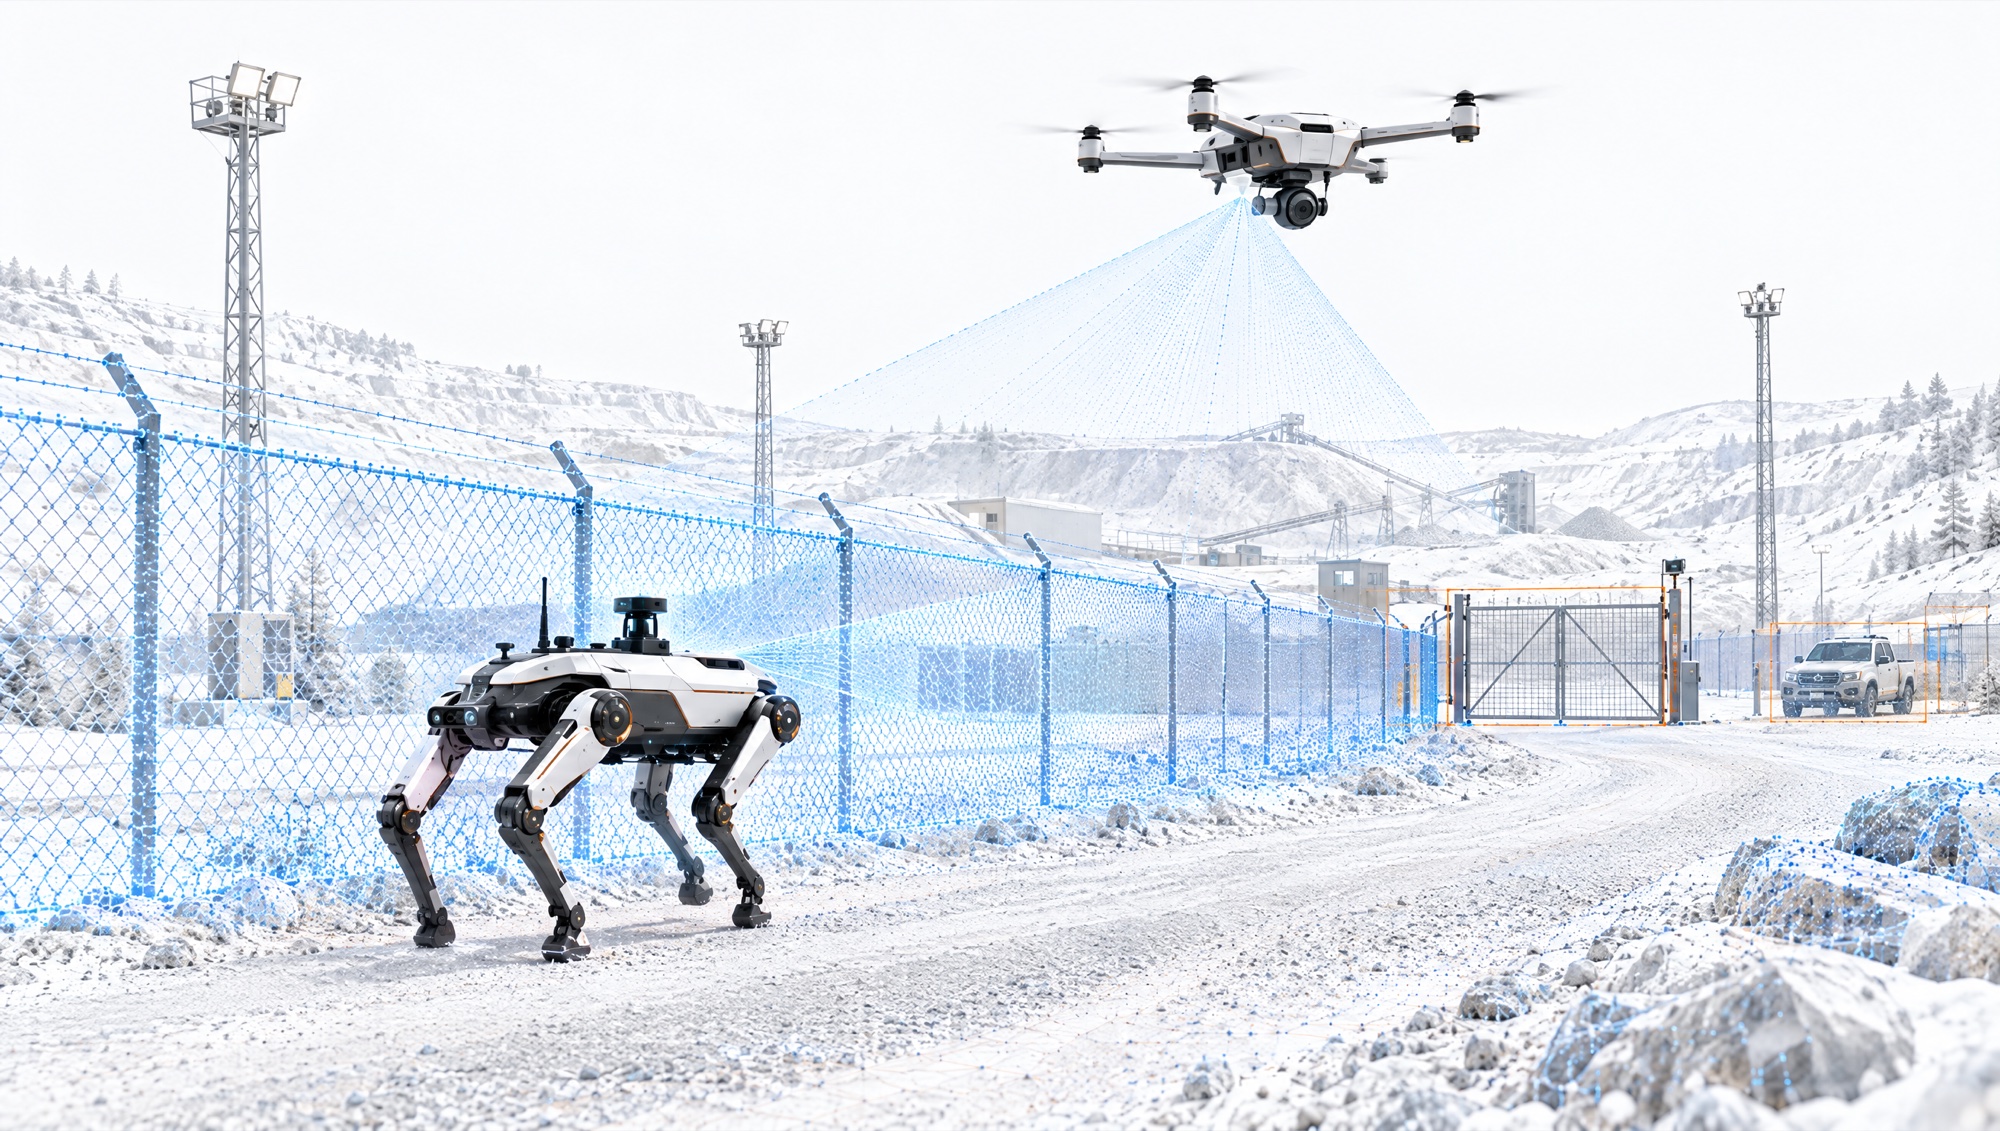
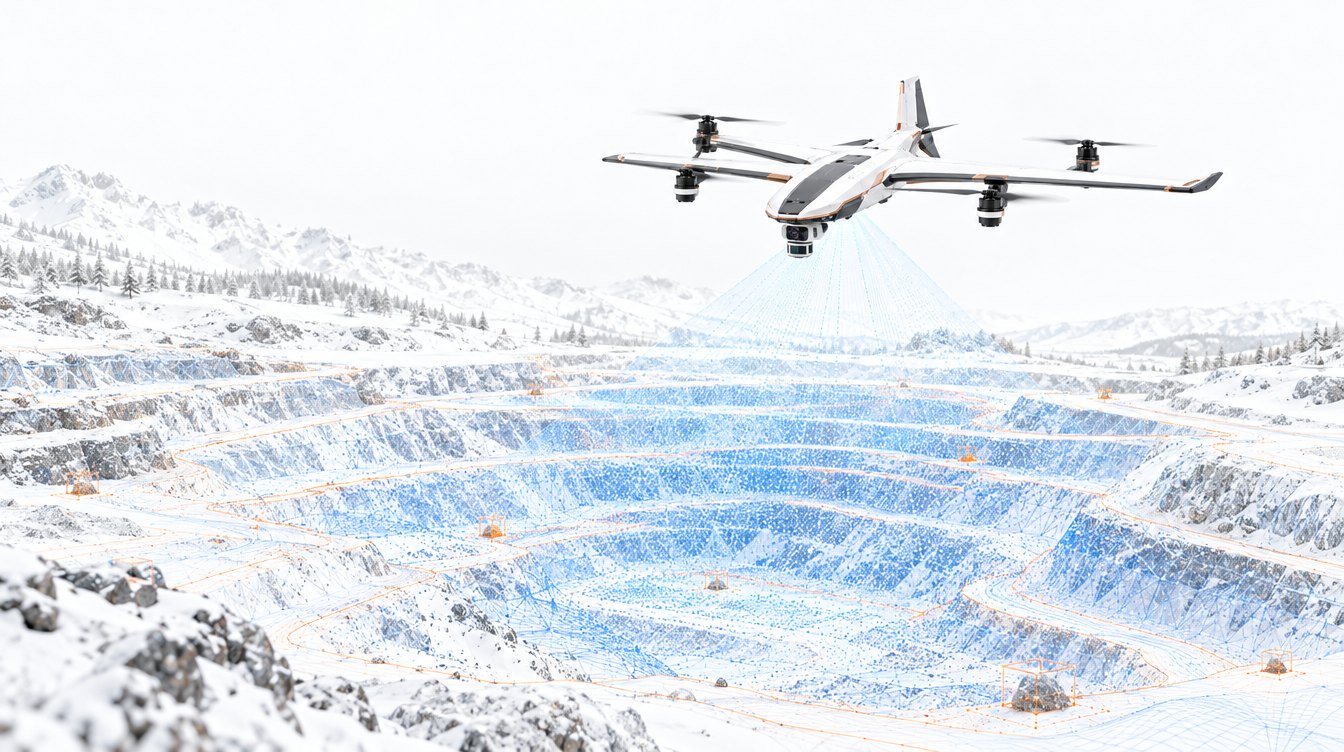
10 · Emergency response and recovery
Build understanding before the next move.
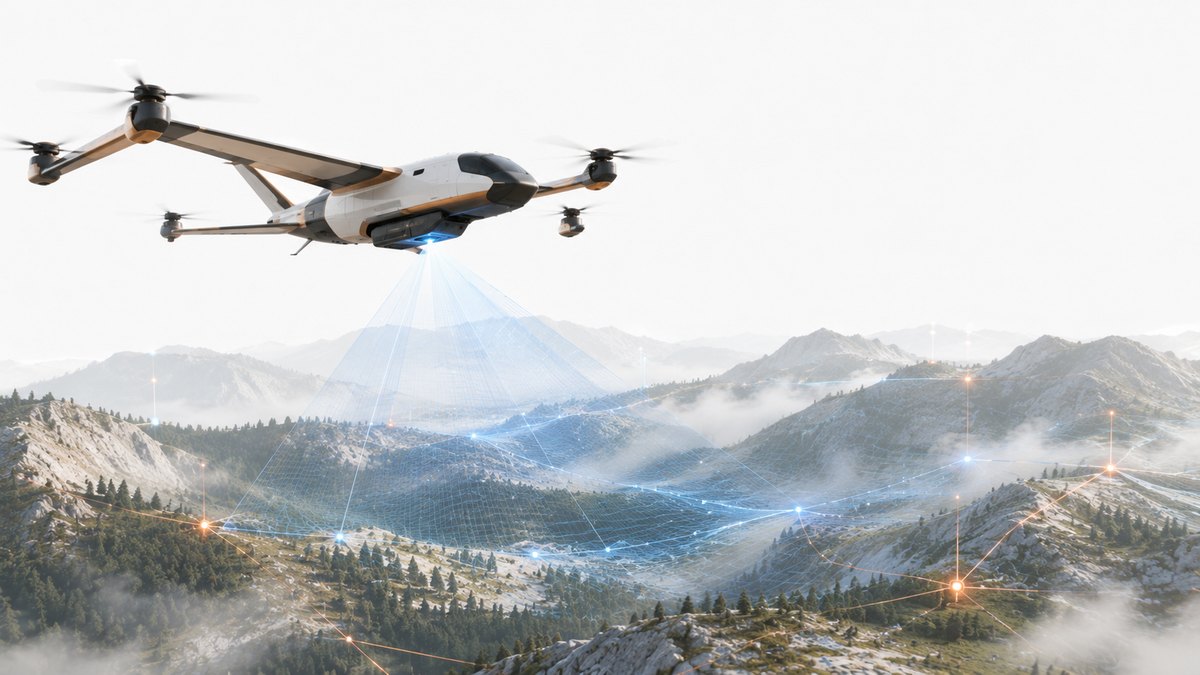
Aerial, legged, and tracked systems could support assessment of affected areas, access-route mapping, light-obstacle handling, and small-supply transport under team supervision.
Collaboration
Define the application with us.
We welcome operators, technical teams, researchers, and response organizations interested in shaping requirements and evaluating potential pilot applications.