Robotics / Aster
Robotic excavation
Aster
Intelligence at the point of excavation.
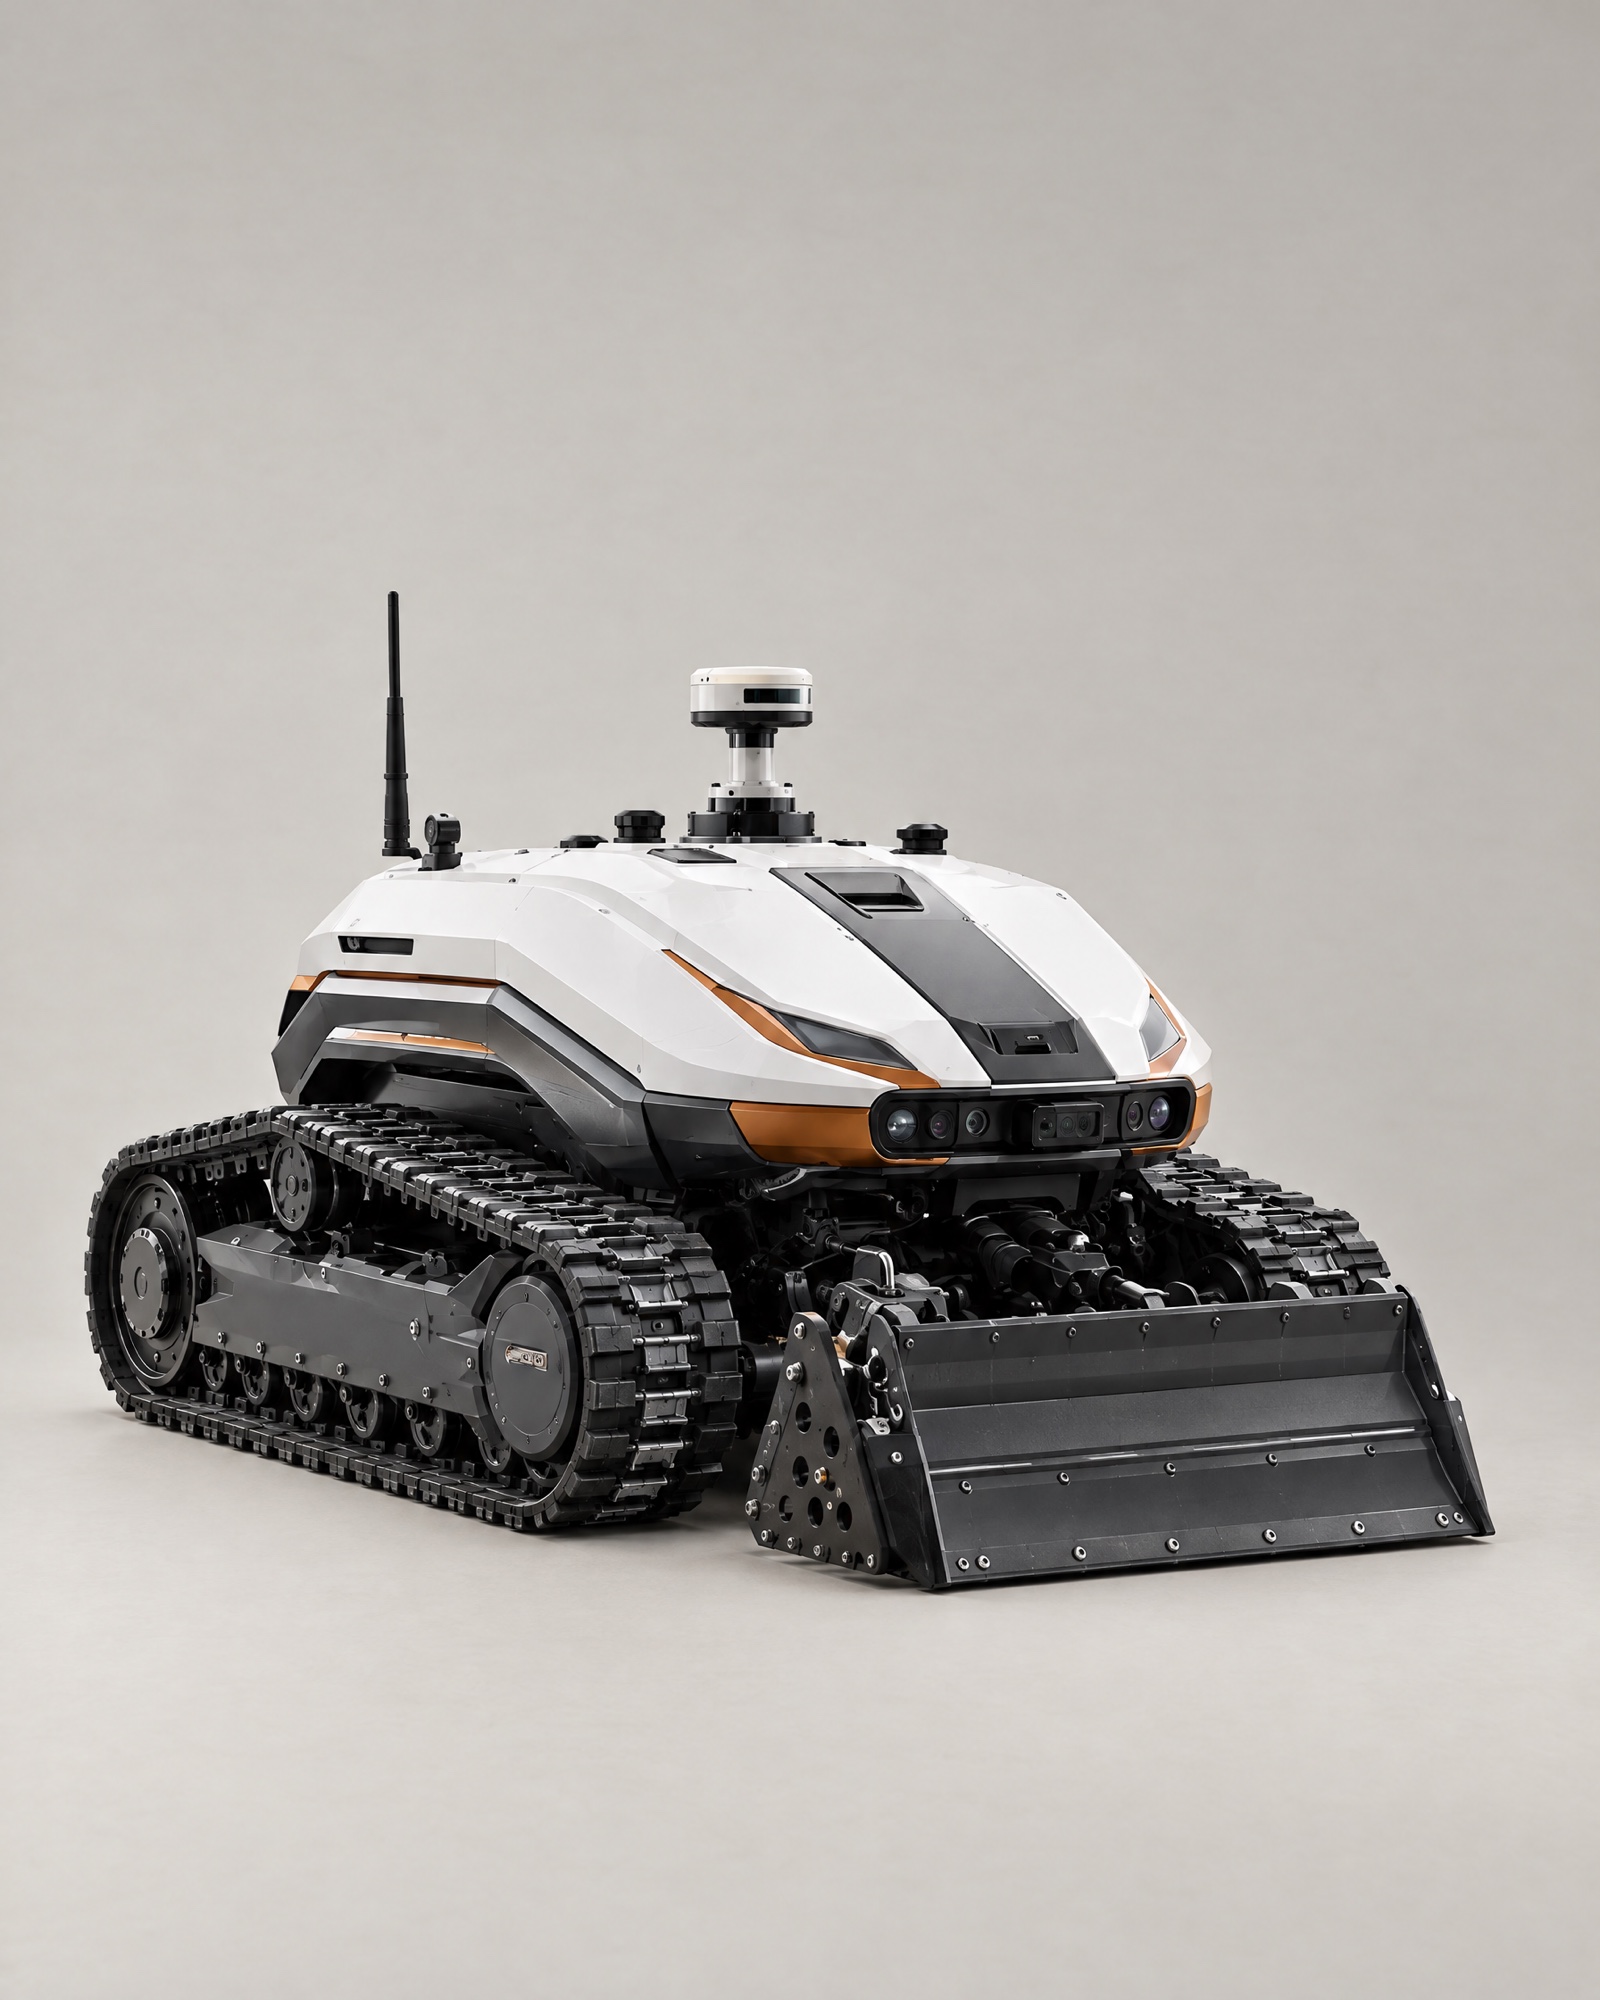
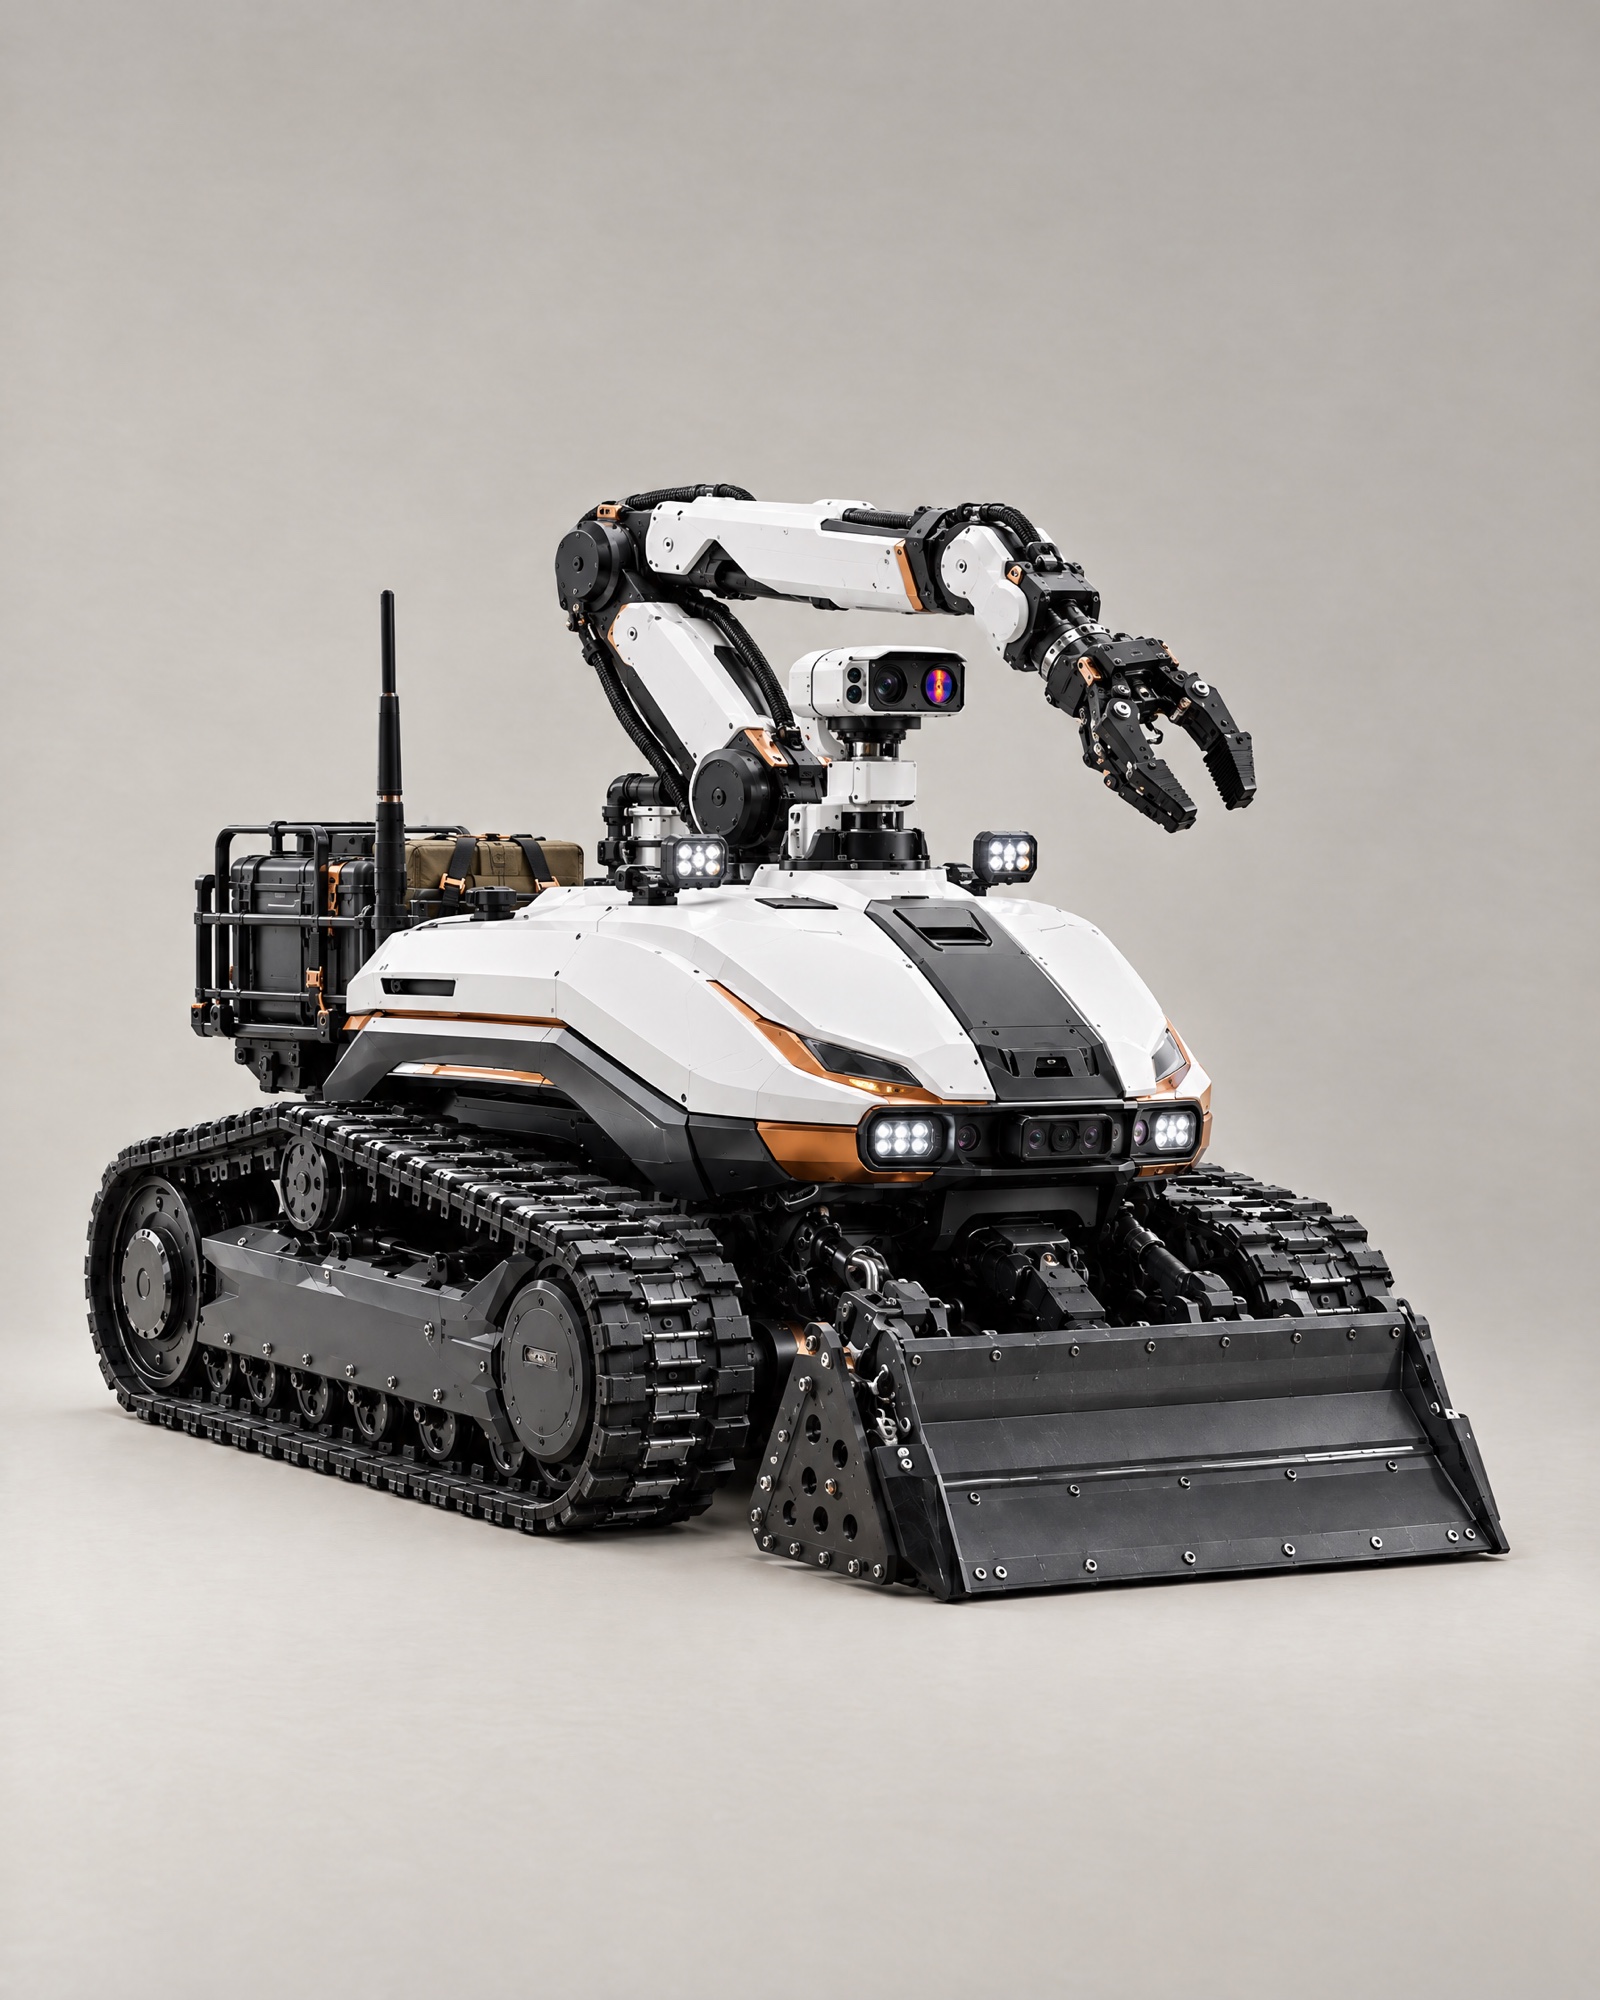
Aster is an excavator robot for digging, material handling, and ground preparation in mining environments.
It combines terrain sensing, robotic control, and operator supervision to support controlled movement within a defined work area.
Discuss an Excavation Application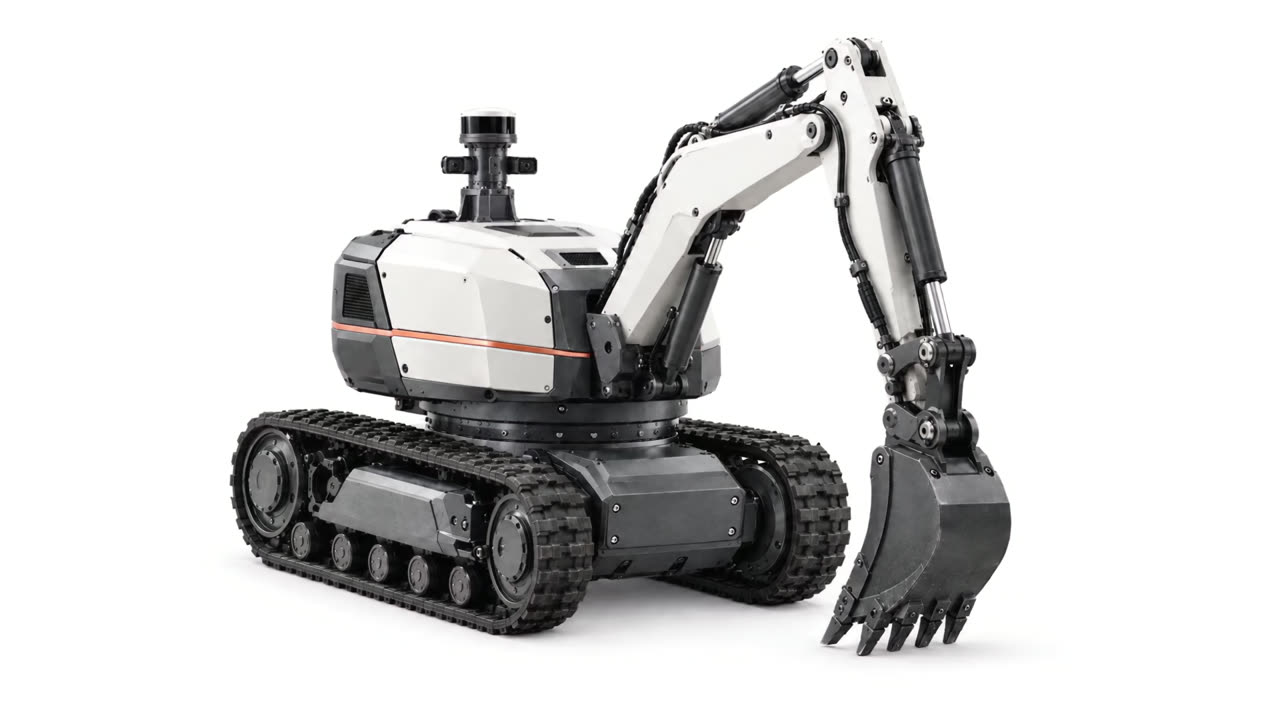
Understand the ground. Control the movement.
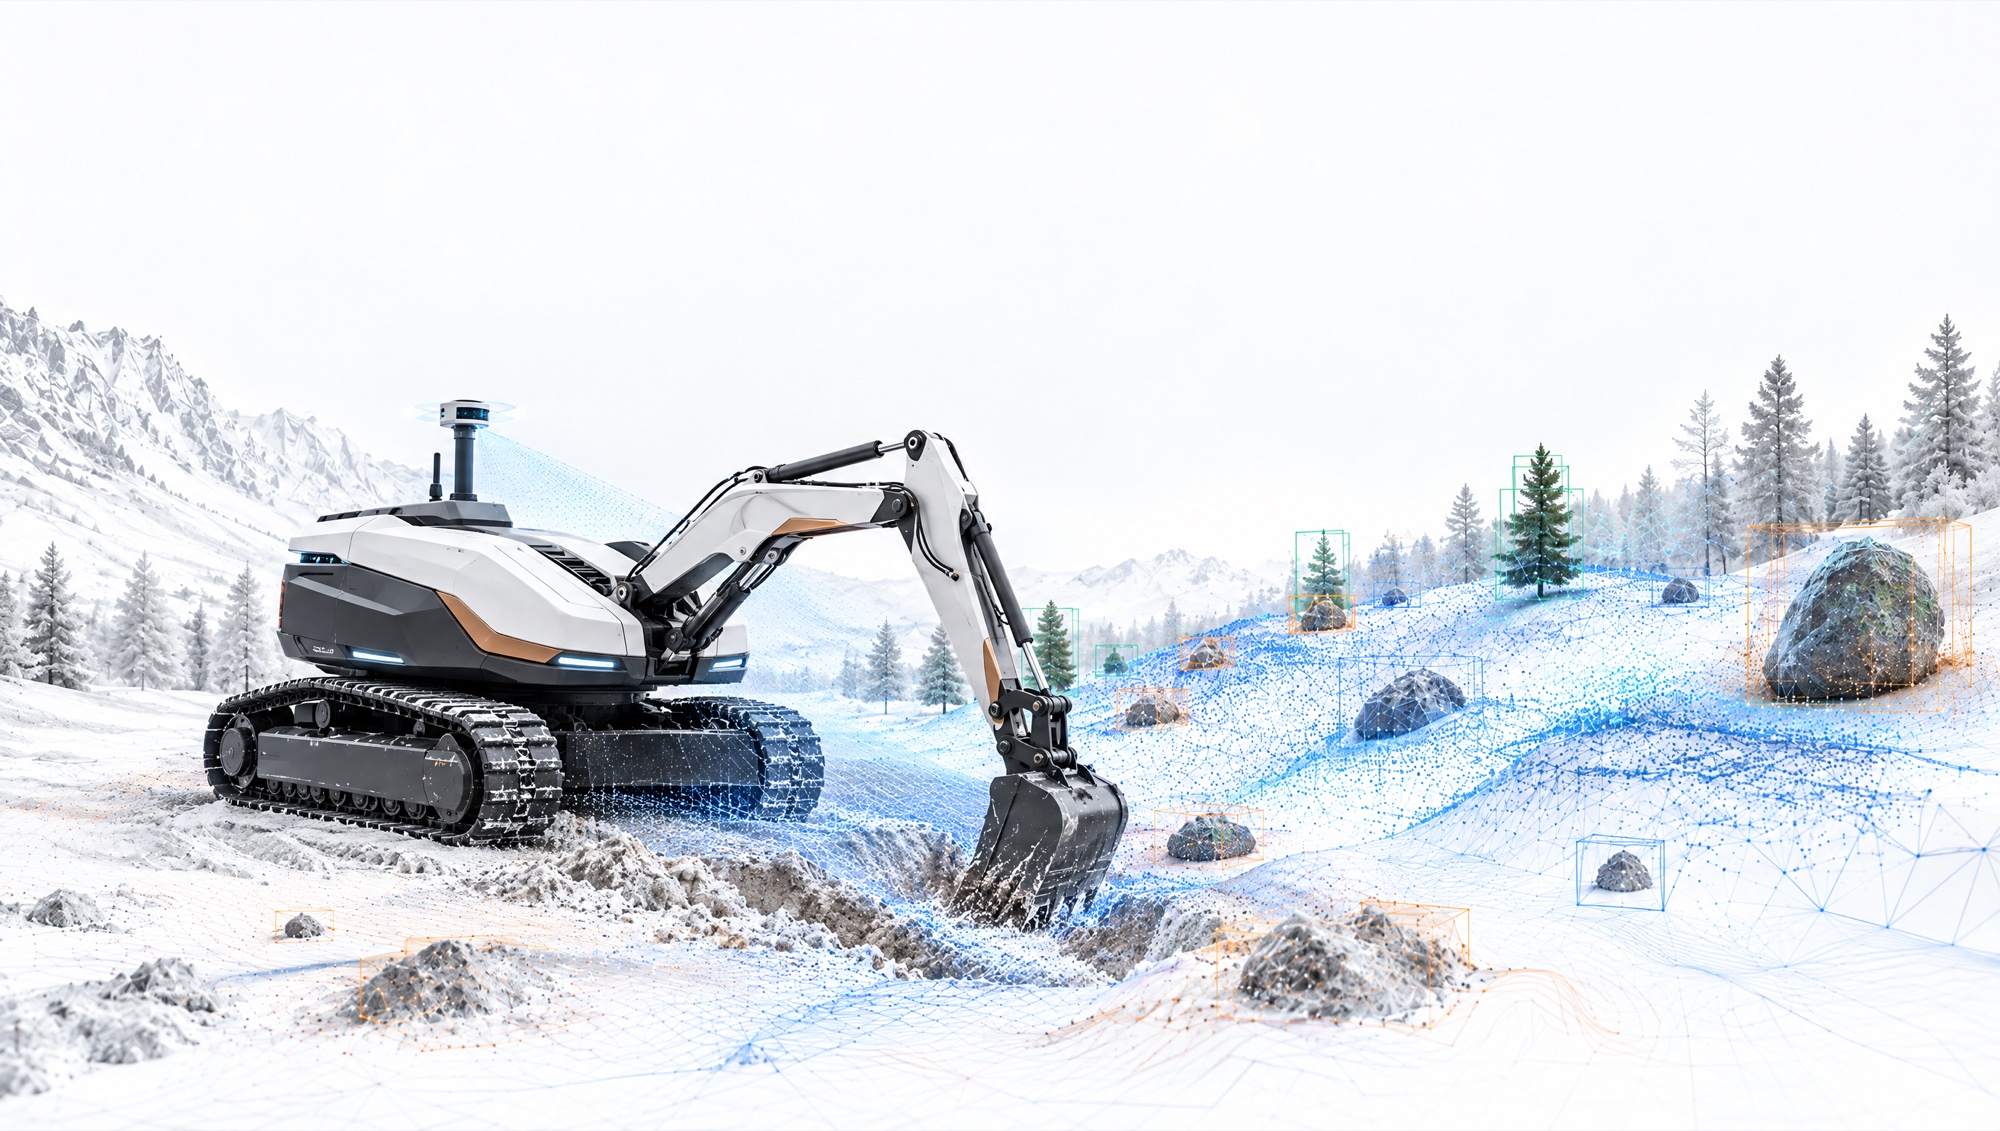
Excavation depends on the relationship between the machine, its tool, the material, and the surrounding work area.
Aster brings these inputs into a coordinated workflow, helping operators plan tasks, supervise execution, and adjust to changing conditions.
Core functions
- 01Robotic digging and material handling
- 02Terrain sensing and work-area mapping
- 03Tool positioning and excavation control
- 04Operator supervision and task control
Define the next excavation challenge.
Other systems
View the full portfolio →